🤝 Top Collaborators
🤓 Latest Submissions
EdgeVLA-Lite
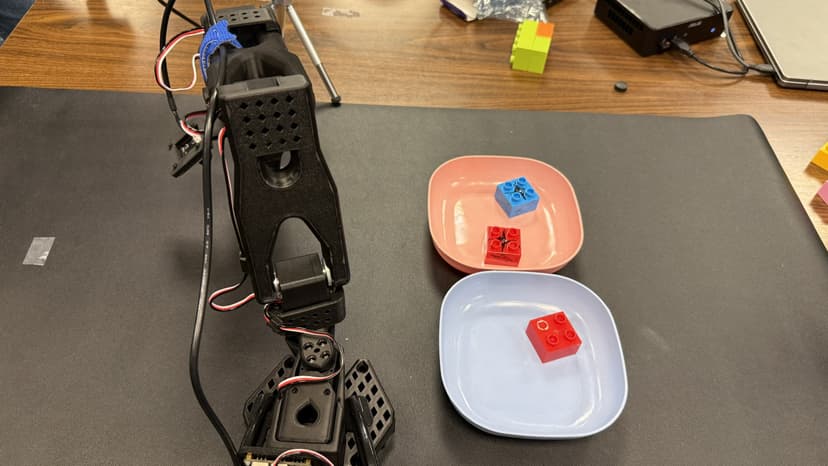
We have built a high-throughput, zero-cloud visual anomaly detection and robotic intervention pipeline tailored for Intel Core Ultra hardware. We utilized the Intel OpenVINO and Anomalib frameworks to perform real-time edge defect localization and lightweight vision classification to output deterministic spatial coordinates for automated sorting or inspection workflows. We are able to successfully demonstrate the Physical AI ability of Intel's robotic arms through actual communication between the Physical AI Studio where the categorization made was between a lego block with permanent marker on it (categorized as bad), and lego block with no marker (categorized as good). The pipeline used ACT models for initial hop from picking station to inspection station and then moved the correct blocks to two different trays, one for good and one for bad.
16 Sep 2026

