
Aqsa Kanwal@aqsakanwal
5
Events attended
2
Submissions made
Pakistan
1 year of experience
About me
I’m Aqsa Kanwal, a Food Science and Technology student from Lahore, Pakistan, passionate about AI, Python, emerging technologies, and innovation. I’m interested in using technology to solve real-world problems, particularly in food, sustainability, health, and quality. I enjoy learning, problem-solving, and collaborating with others to build practical solutions. I’m joining Lablab.ai to participate in AI hackathons, connect with talented people, and combine my Food Science background with AI to create meaningful projects.
🤝 Top Collaborators
🤓 Latest Submissions
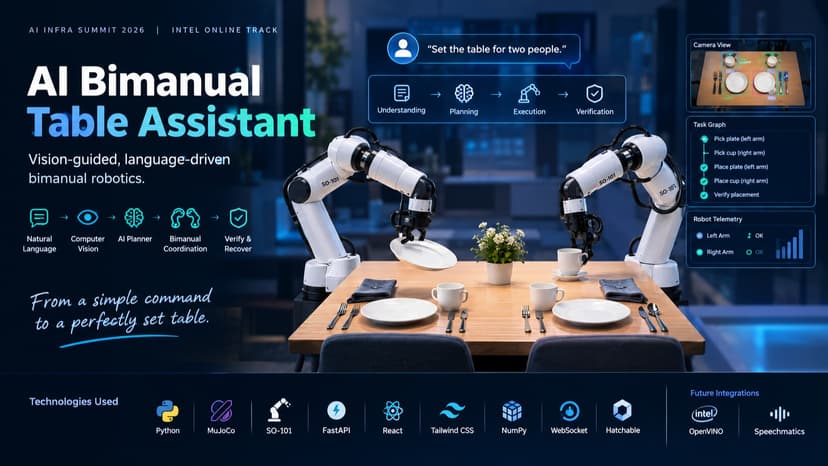
AI Bimanual Table Assistant
AI Bimanual Table Assistant is a vision-guided robotics system designed to transform natural-language instructions into coordinated physical manipulation tasks using two SO-101 robotic arms in MuJoCo. The system accepts commands such as “Set the table for two people” and converts them into a structured, dependency-aware task graph containing pick, move, place, and verification actions. A world model maintains object identities, classes, positions, robot joint states, and simulation telemetry. The architecture connects natural-language understanding, camera-based scene observation, AI task planning, bimanual task allocation, inverse kinematics, motion planning, robot control, MuJoCo physics, placement verification, and failure recovery. The local runtime uses Python, MuJoCo, and FastAPI, while the hosted Hatchable control plane provides the web dashboard, hosted task-planning experience, deterministic safety fallback, and browser-safe simulation preview. The project is designed around a closed-loop robotics principle: Plan → Execute → Observe → Verify → Recover. The system never treats an AI-generated plan as proof of physical success. Future integration includes Intel OpenVINO for optimized vision inference, Speechmatics for streaming voice commands, collision-aware motion planning, physical grasp execution, benchmark evaluation, and advanced recovery/replanning.
16 Sep 2026


