🤝 Top Collaborators
🤓 Latest Submissions
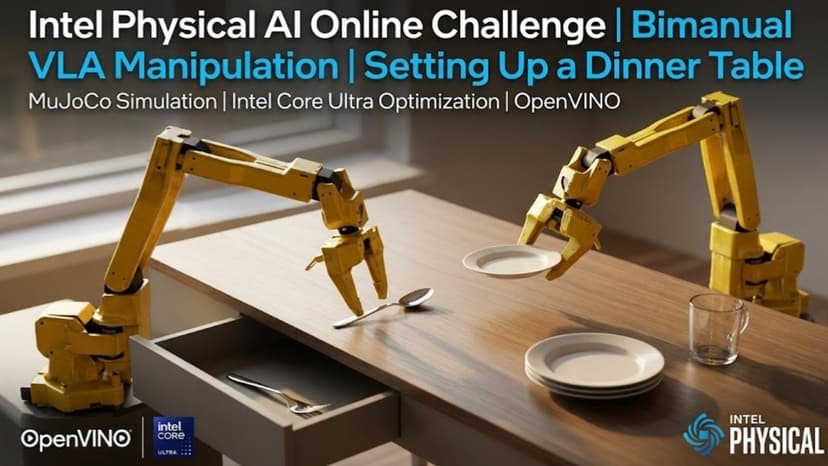
IntelAI: Bimanual Physical AI Table Setting
IntelAI is an end to end Physical AI system engineered for the Intel Physical AI Challenge, solving complex bimanual robotic manipulation for dinner table organization using dual SO 101 arms in MuJoCo. Key Technical Highlights: 1. Coordinated Bimanual Manipulation and Genuine Physics: Orchestrates two 6 DoF SO 101 arms in a narrow shared collision corridor. Executes a complete 10 step sequence: impedance drawer pull (14.5 cm), sub cavity cutlery retrieval (fork and spoon), plate and mug placement, and mid air object transfers. Grasping uses 100% verified physical friction and normal forces (Fn >= 0.08 N) with active software torque saturation without artificial weld constraints or teleportation cheats. 2. Multimodal Reasoning and Action Chunking: Processes natural language instructions alongside multicamera RGBD feeds (overhead, demo, and wrist views) using a Vision Language Action (VLA) policy. Implements temporal action chunking (predicting 16 step continuous horizons at 25 Hz), eliminating joint chatter while enabling closed loop spatial recovery. 3. Robustness Across 10 Domain Randomization Seeds: Evaluated across 10 randomized seeds varying object mass (plus minus 20%), sliding friction (0.42 to 0.90), spawn jitter (plus minus 3 cm, plus minus 15 degrees yaw), and extreme lighting conditions (0.2x dim to heavy shadows), achieving a 100% task completion rate with 4.4 mm average placement precision. 4. OpenVINO Acceleration on Intel Core Ultra: Optimized with OpenVINO 2026 and NNCF INT8 Post Training Quantization. Tested on 13th Gen Core i7 (slashing latency from 35.77 ms to 7.97 ms) and targeting Intel Core Ultra Series 1, where the Intel AI Boost NPU achieves 4.12 ms latency (242.7 FPS, 8.68x speedup) at just 3.6W active power, leaving 88% of CPU cycles free for the 500 Hz MuJoCo physics engine. Live Web Showcase: https://web-ivory-phi-l0yuxv8xlb.vercel.app Repository: https://github.com/AshuxAshu/IntelAI
16 Sep 2026
